Edge-to-Edge Mesh
Decentralised coordination that keeps working in degraded, denied and zero-RF conditions.
Edge-to-Edge Mesh →VIPER
Coordinate heterogeneous aerial, ground and maritime assets as a unified operational force through mission orchestration, shared awareness and distributed autonomy.
Modern missions increasingly depend on distributed platforms and intelligence systems.
But these systems often operate within separate control architectures and vendor ecosystems. Their data remains local to the system that produced it, making it difficult to correlate events across the network or maintain a common mission picture.
The result is a mission constrained by its interfaces:
Signals detected in isolation rather than correlated across sensors and platforms.
Event timelines fragmented across independent systems.
Platform state and intelligence separated from the mission context needed to act on them.
Operators managing individual systems instead of directing the mission.
Every new platform adds another interface, control logic and training burden.
VIPER is built to close that gap.
By the numbers
Placeholder metric one01
64 Placeholder supporting linePlaceholder metric two02
98% Placeholder supporting linePlaceholder metric three03
2,500+ Placeholder supporting linePlaceholder metric four04
15 Placeholder supporting lineThe Mission Layer
VIPER sits above existing platforms, sensors and control systems, connecting their capabilities through a common mission layer. It gives operators a shared environment to define mission intent, allocate tasks and coordinate execution across the network.
Platform state, sensor inputs and intelligence are brought into the same mission context, allowing distributed systems to contribute to one coordinated objective.
 Satellite
Fixed-wing UAV
Heavy-lift UAV
Recon UAV
UGV
RF Sensor
Comms Relay
USV
ISR UAV
Operator
VIPER Mission OS
Operating Model
Coordinate heterogeneous platforms around a common mission objective.
Enable platforms to execute defined tasks while operating as part of a larger mission.
Combine platform state, telemetry and sensor inputs into a common view of the mission.
Reassign tasks as mission objectives, platform state and operating conditions change.
Identify and distinguish friendly platforms through mission context and multiple sources of information.
Coordinate multiple autonomous platforms to execute a shared objective with distributed tasking and coordinated behaviour.
Integrate existing and future platforms across manufacturers and domains without replacing the underlying infrastructure.
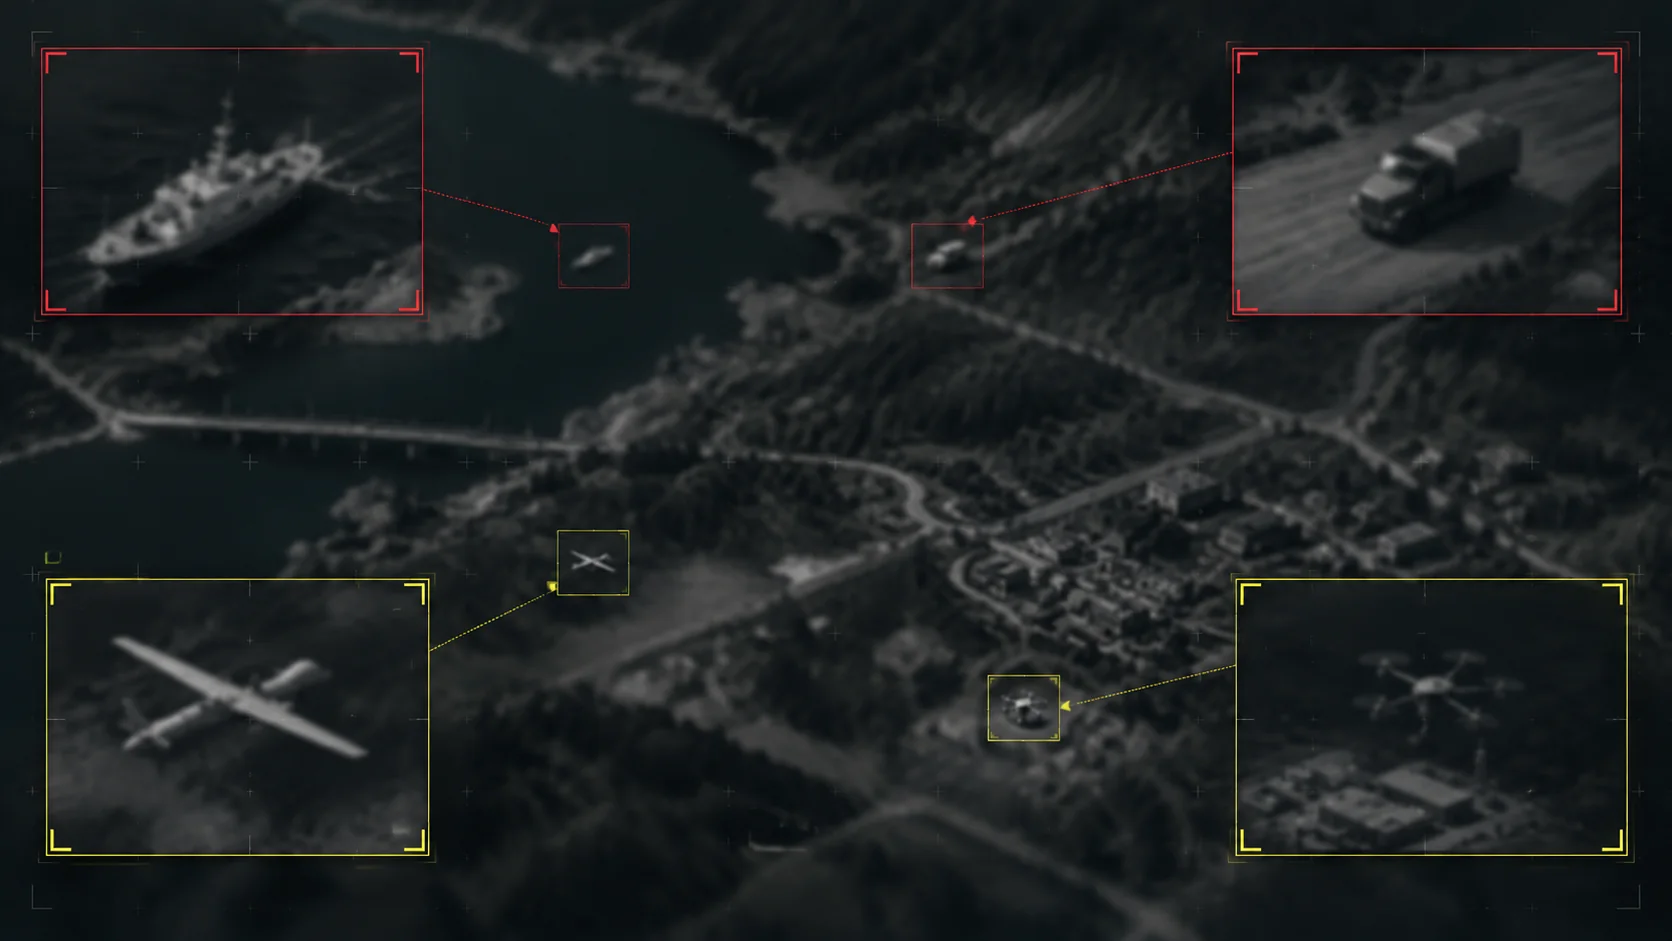
Classify and detect potential threats using distributed sensor inputs and mission context.
 Coming soon
Edge Autonomy
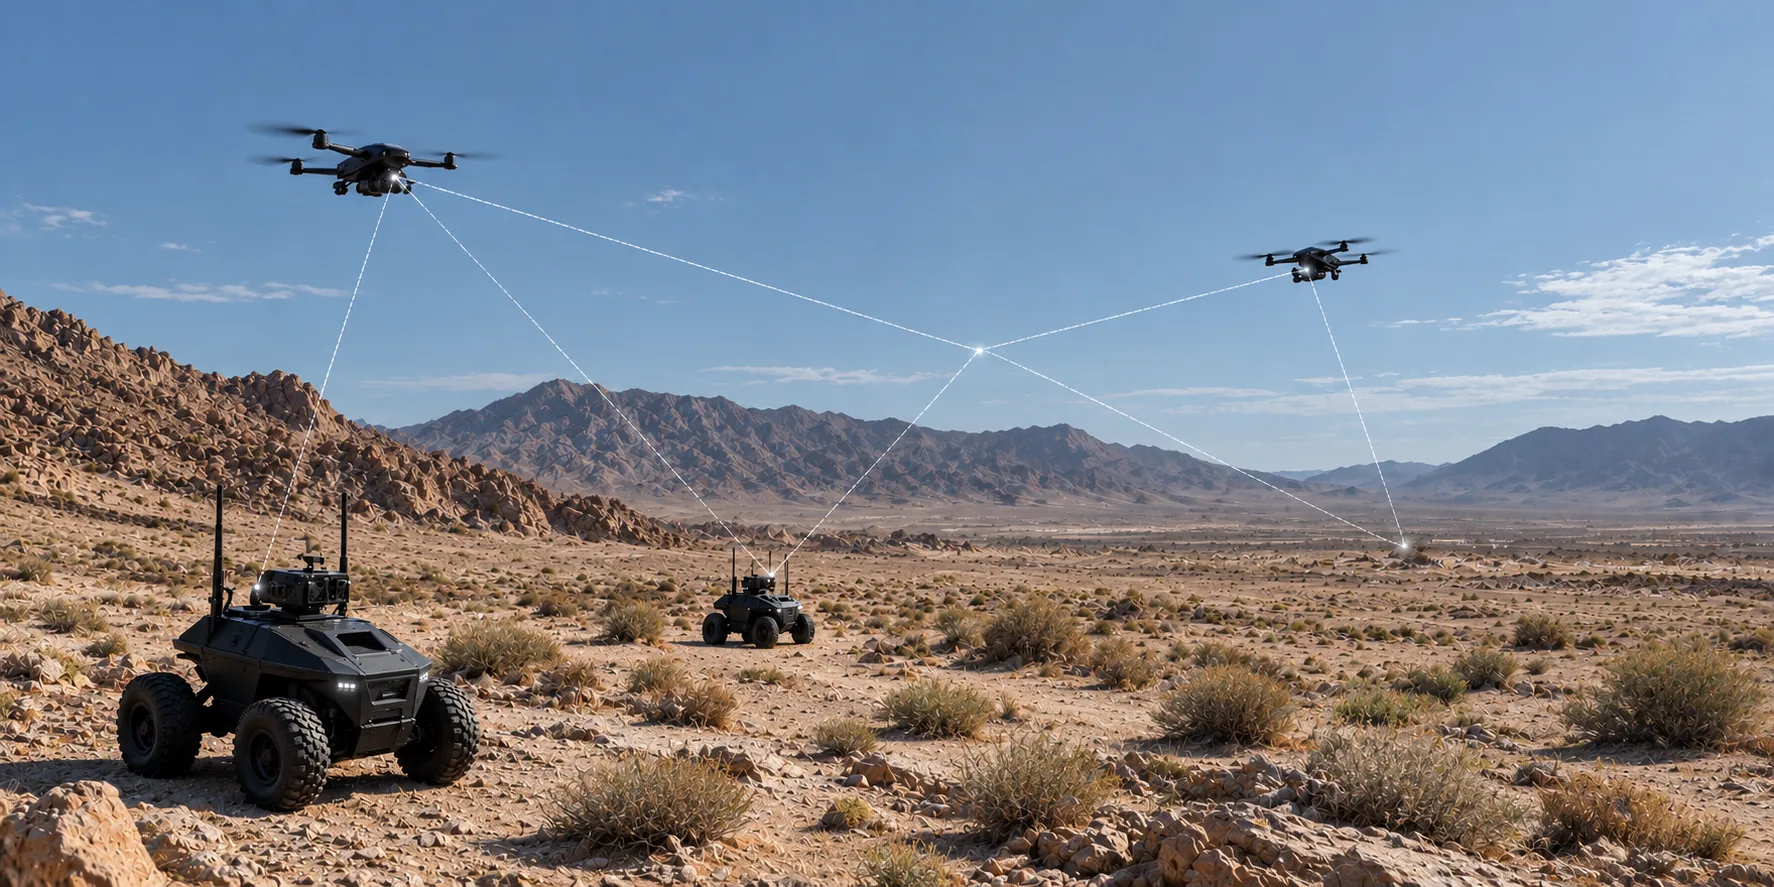
VIPER distributes mission logic to the edge through Scout, the Driif Edge Agent. Running on the platform, Scout enables local decision-making and mission execution when connectivity to the control layer is degraded while keeping operators responsible for mission intent and critical decisions.
Scout executes mission logic at the edge, without relying on continuous GCS or cloud connectivity.
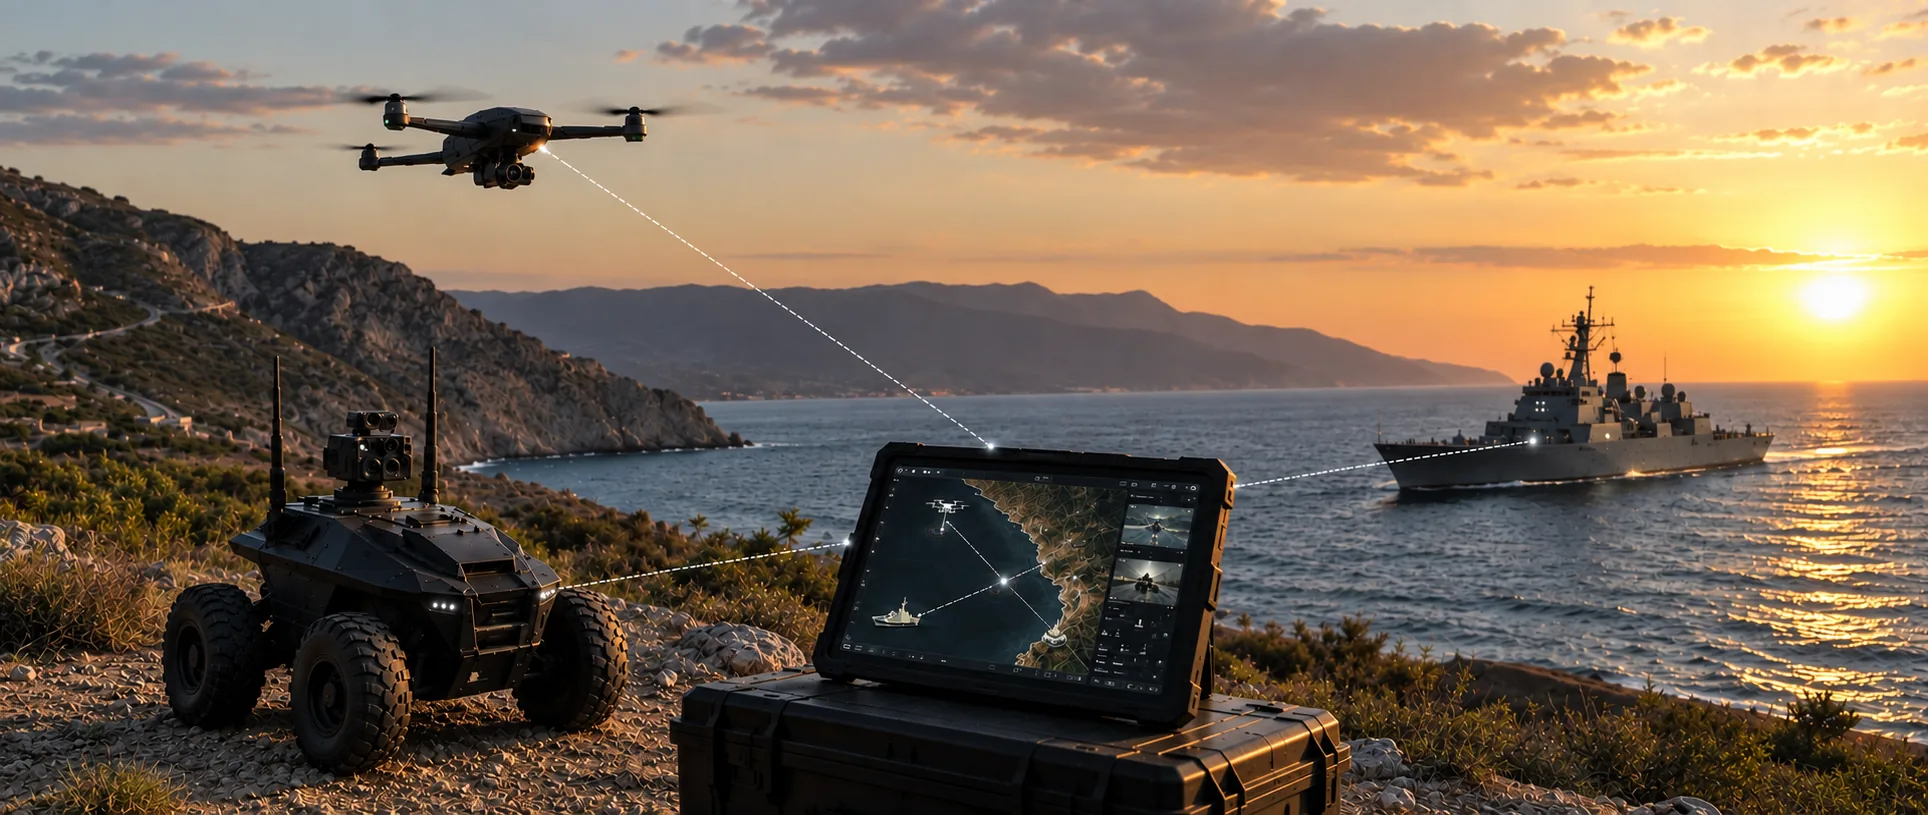
Operators retain control over objectives, rules and critical decisions.
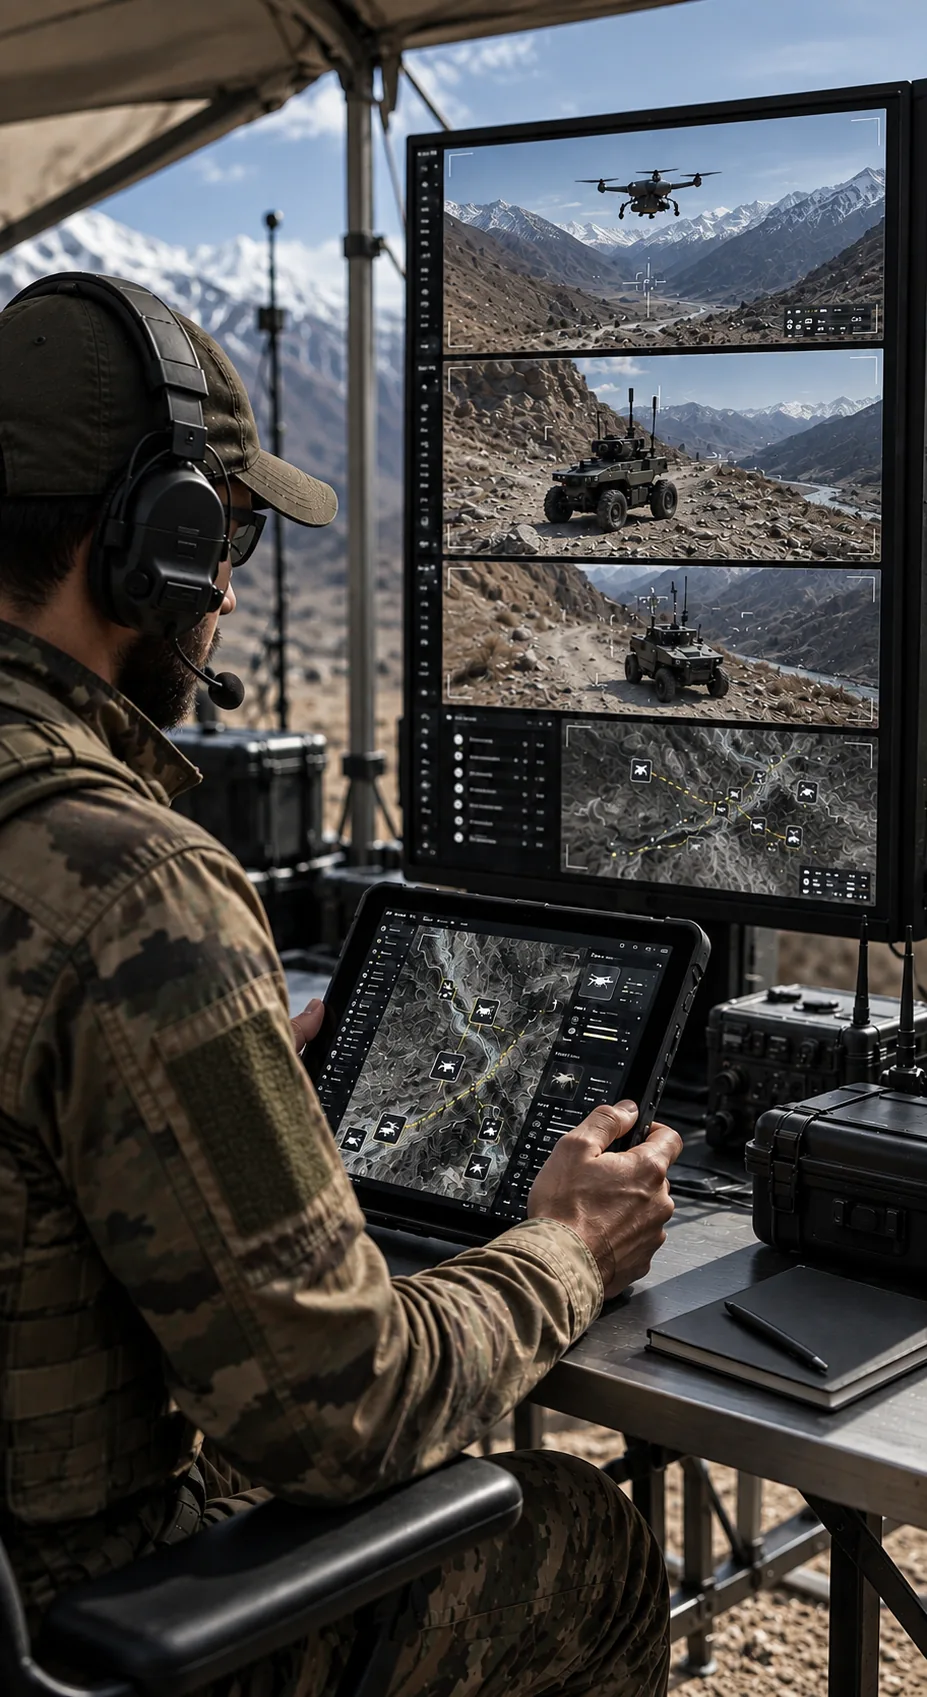
Mesh networking and synchronized timelines maintain coordination in contested or degraded environments.
The Operator Experience
Faster induction, lower training cost per operator, a force that scales with procurement.
APIs and integration platforms move data between systems but can’t orient, decide, or act at mission speed.
A decision layer built to allow you to act at the pace the mission needs.
Single-vendor systems lock you into one OEM’s ecosystem.
Hardware-agnostic. Works with what you’ve already deployed, from any manufacturer.
OEM-specific control room per platform.
An operator trained on VIPER can command every platform in the fleet.
Every new platform means retraining.
New platforms inherit the same command logic and interface.
Operators overloaded in high-tempo ops.
Edge autonomy handles real-time classification and rule enforcement. Operators focus on decisions, not babysitting platforms.
Every Platform
Loitering munitions, one-way attack, ISR, interceptors, FPVs and more. VIPER tasks the platforms you already field and orchestrates them as one force, under one operator.
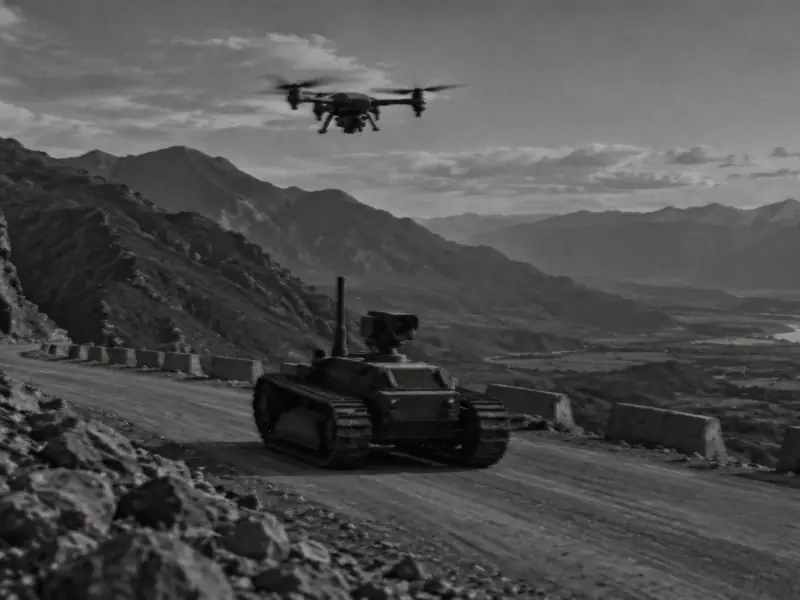
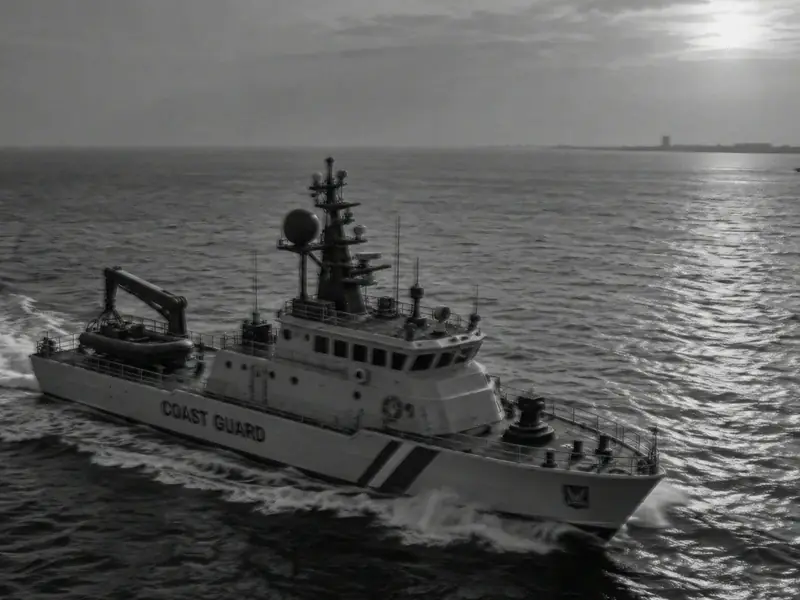
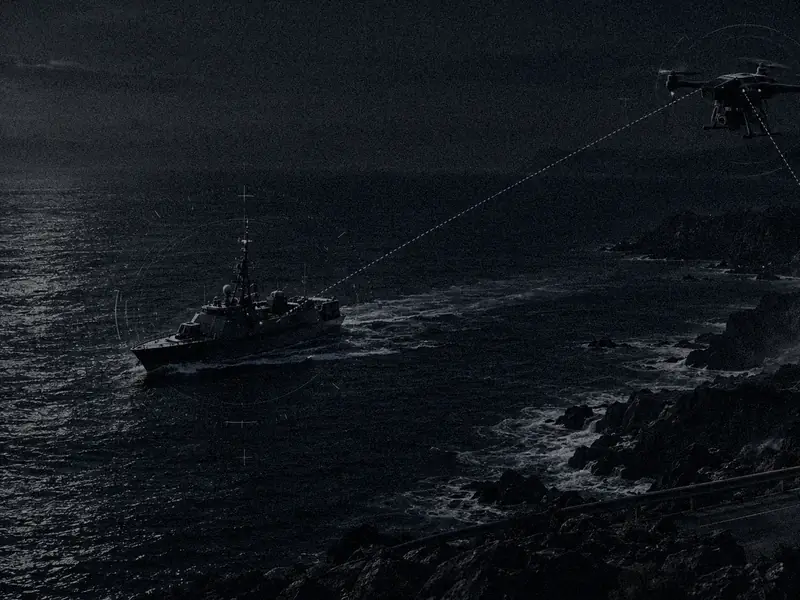
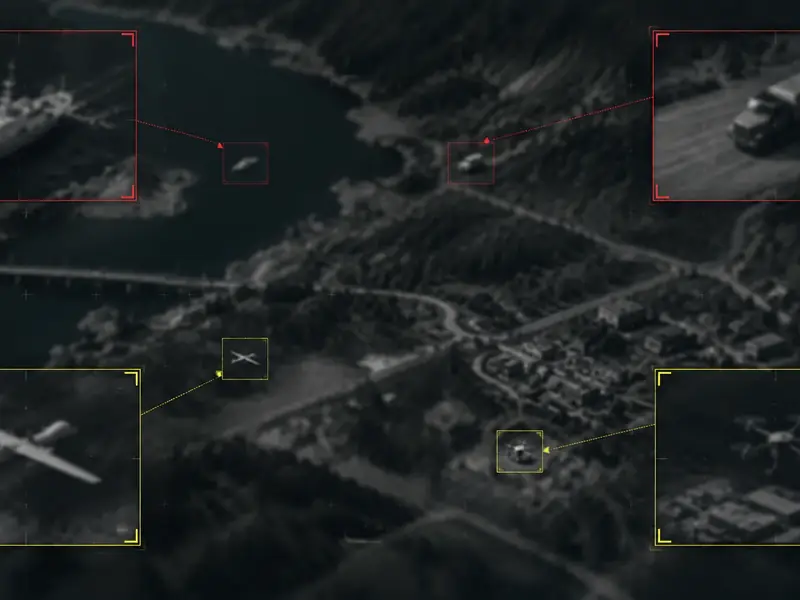
Representative platform classes. Integration status for specific platforms on request.
Runs on Driif Mission OS
VIPER runs on Driif Mission OS: the same mesh, autonomy and edge perception that sit under every Driif mission.
Decentralised coordination that keeps working in degraded, denied and zero-RF conditions.
Edge-to-Edge Mesh →One operator sets intent; mixed fleets divide the work under human authority.
Mission Autonomy →Post-Mission Debrief
Modern operations are increasingly defined by an imbalance between sensor input and operator capacity—too much raw data and operator workload, and too little time, coverage, and decision space. Driif AI’s Scout Systems expands awareness, reduces manual search, and enables faster, more confident decisions.
Cooperative and non-cooperative, resolved at the edge.
Threat identification and classification without a datalink.
Designation and handoff inside the engagement loop.
Cooperative behaviour, no central controller.
Scout is in pre-production testing. Performance data, integration detail and trial results are available under NDA.
Get Started
Bring your heterogeneous platforms and systems into one mission environment.
Request a demo